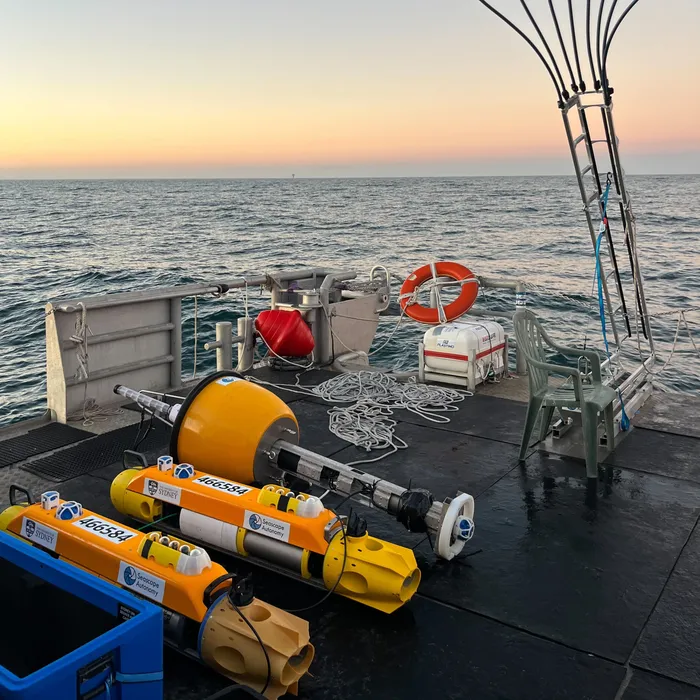
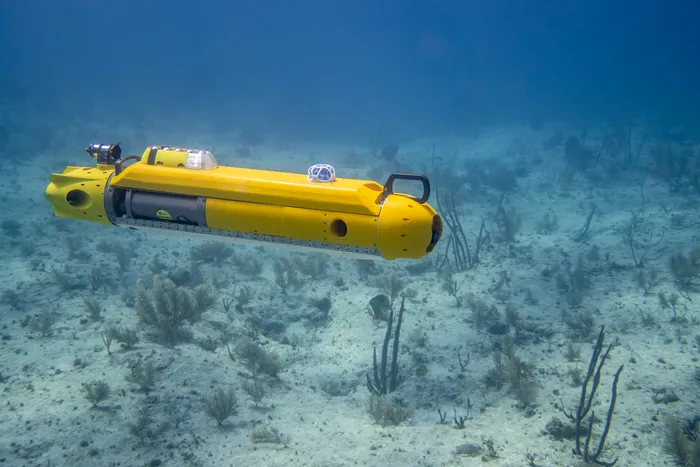
The Seeker AUV is a two-person portable, modular, hover-capable and highly manoeuvrable AUV developed at the Australian Centre for Robotics. Designed for capturing low-altitude, high-resolution, geo-referenced seafloor imagery over complex underwater terrain, it can also be readily reconfigured for novel optical, acoustic and water-column sensing missions.
It can hold position, dive vertically and move in constrained spaces around man-made structures, behind the breaking waves of a beach or over rough reef environments, all while staying close to the seafloor.
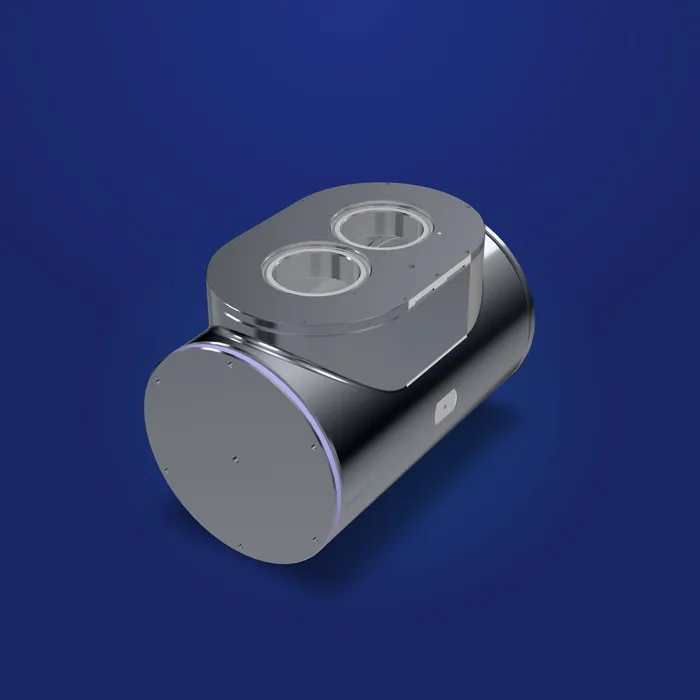
Its open software and hardware architecture allows additional payloads to be integrated without significant cost in materials or development effort. The nose and forward regions provide space for additional sensors, including optical or hyperspectral cameras, sonar systems or water-column sensors. The vehicle frame can also be extended for additional payload space or battery capacity, further increasing endurance.