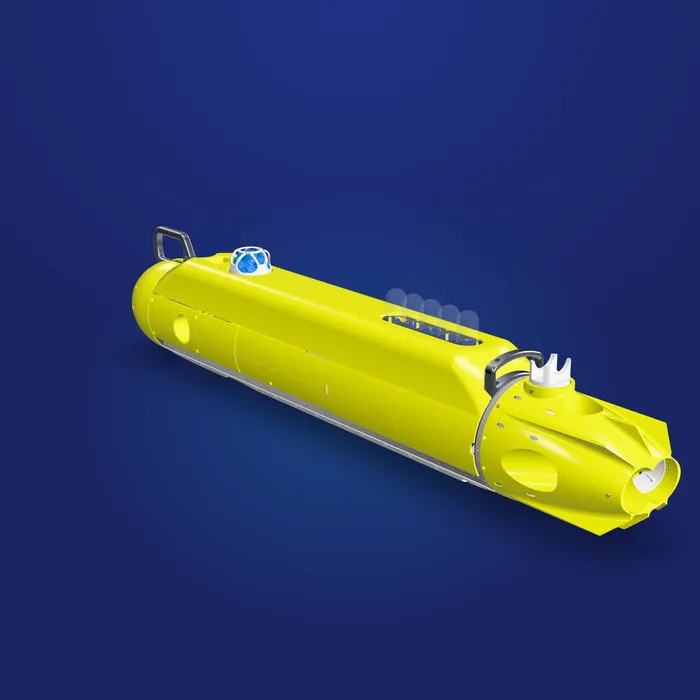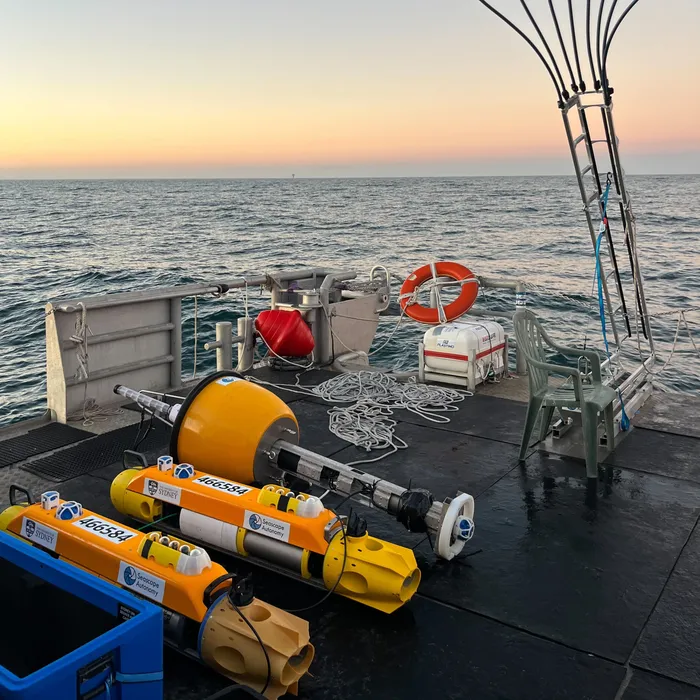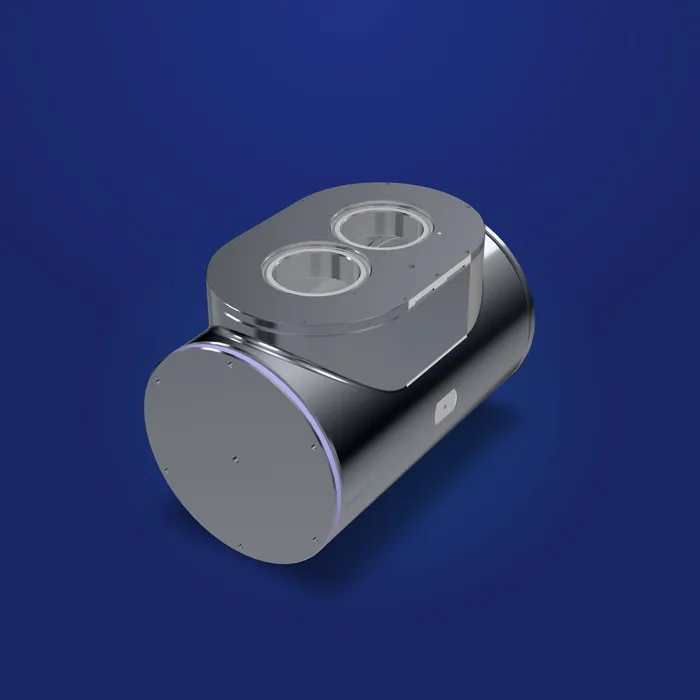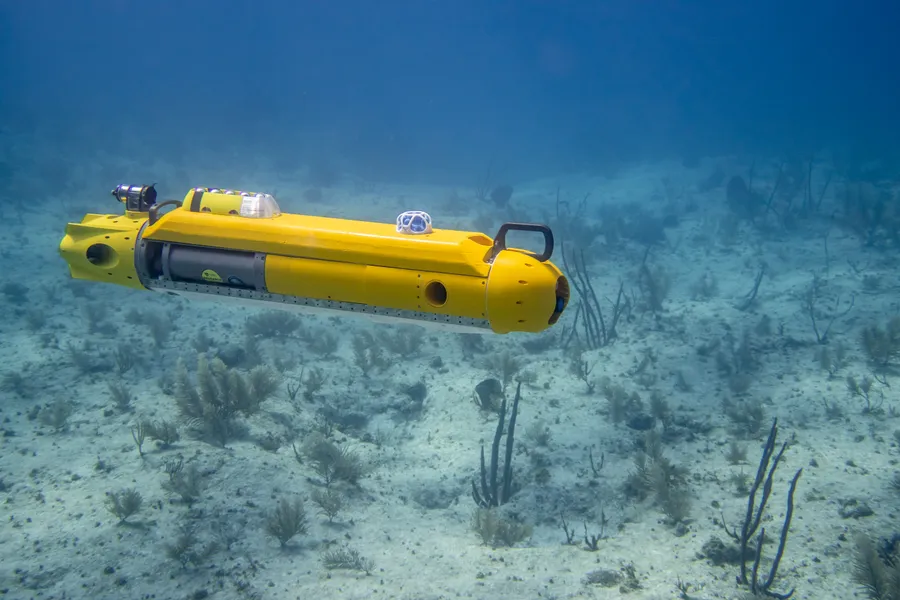
The Seeker AUV’s open software and hardware architecture allows additional payloads to be integrated without significant cost in materials or development effort. The nose and forward regions provide space for additional sensors, including optical or hyperspectral cameras, sonar systems or water-column sensors.
The vehicle frame can also be extended to allow for additional payload space or battery capacity, further increasing endurance. Tell us about your mission and we’ll work with you on the right configuration.